Robotphoenix H100/H200 Humanoid Robot Chassis is a next-generation robotic mobility platform designed to accelerate the development and deployment of embodied intelligent robots. Combining advanced motion control technology, high-performance joint modules, intelligent power management, and flexible hardware architecture, the H100/H200 provides a reliable foundation for building future humanoid robot applications.
Designed as a modular humanoid robot platform, the H100/H200 enables researchers, developers, and industry partners to explore intelligent robotic applications including AI perception, autonomous motion, human-robot interaction, intelligent manufacturing, service robotics, and embodied intelligence research.
Powered by Robotphoenix’s expertise in industrial robotics and intelligent automation, the H100/H200 bridges the gap between robotic hardware and artificial intelligence, enabling robots to better understand environments, execute complex movements, and interact naturally with the physical world.
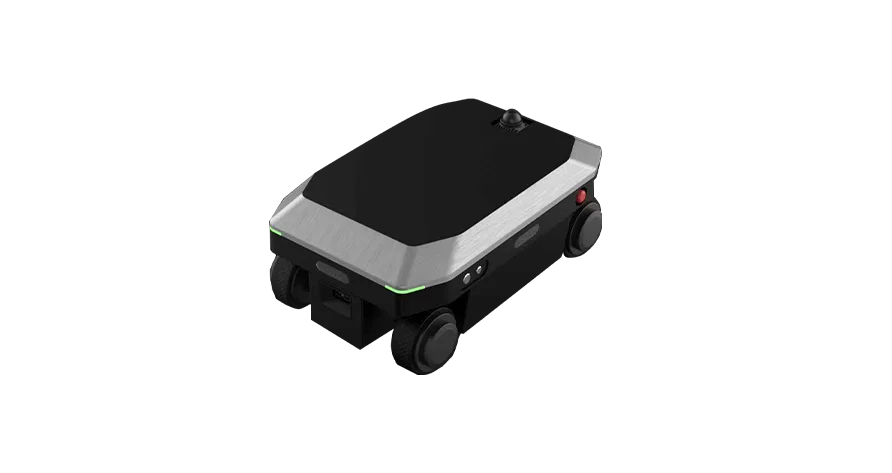
| Technical Specifications | |
| Overall Dimensions | 720 × 550 × 335 (±2) mm |
| Turning Diameter | 850 mm |
| Net Weight | 70 kg |
| Rated Payload | 200 kg |
| Ground Clearance | 40 mm |
| Lifting Platform Dimensions | — |
| Human-Machine Interface | — |
| Lifting Drive | — |
| Lifting Height | — |
| Rated Operating Speed (Rated Payload / No Load) | 72 / 90 m/min |
| Acceleration (Rated Payload / No Load) | — |
| Rotational Speed (Full Load / No Load) | — |
| Drive Configuration | Four-Wheel Omnidirectional Drive |
| Navigation | LiDAR SLAM |
| LiDAR Installation Height | — |
| Parking Positioning Accuracy | ±10 mm |
| Parking Orientation Accuracy | ±1° |
| Battery Type | LiFePO₄ / Ternary Lithium (Optional) |
| Capacity / Rated Voltage | 20 / 48 + 40 / 48 Ah/V (Optional) |
| Charge/Discharge Cycles | — |
| Operating Time at Rated Conditions | — |
| Charging Time from Full Discharge | — |
| Front LiDAR Obstacle Detection (Quantity / Installation Height) | 310.5 mm |
| Scanning Angle | 270° |
| 3D Vision-Based Obstacle Avoidance | Optional — Front / Rear / Left / Right |
| Rear Ultrasonic Sensors | — |
| Emergency Stop Buttons | 2 (One on Each Side) |
| Contact Safety Protection: — | — |
| Audible & Visual Alarm | Standard |
| Chassis Shock Absorption | — |
| Maximum Gradeability | — |
| Step-Climbing Capability | — |
| Gap-Crossing Capability | — |
| Operating Environment | |
| Operating Environment | Indoor |
| Floor Conditions | Hard concrete or conductive plastic flooring recommended. The operating surface must be free of metal debris, oil contamination, corrosive liquids, and other obstructions. Floor joints should be avoided; where unavoidable, joints should not exceed 10 mm. Maximum floor gradient: 8°. At precision positioning points: ≤1°. The floor coefficient of sliding friction should be ≥0.5 to ensure braking safety and positioning accuracy. |
| Operating Temperature | −10°C to 40°C |
| Charging Temperature | 0°C to 40°C |
| Relative Humidity | 10%–90%, non-condensing |
| Wireless Communication | Dual-Band Wi-Fi 2.4 GHz / 5 GHz; Signal Strength > −70 dBm |
© 2026 ROBOTPHOENIX. All Rights Reserved.
Designed by AdmarV